About Me
I am working on Robot Policy Learning and Geometric Learning at The Helping Hands Lab in Northeastern University, advised by Professor Robert Platt and PhD Candidate Haojie Huang. Some of my work collaborates with Boston Dynamics AI and Li Auto. Previously, I conducted research on multiple robotics and computer vision topics: Deep Learning Optimization for 3D Vision, FDM Printing for Soft Robotics, and an Automated Healthcare Monitoring System. My past research works were supervised by Prof. Ziming Zhang at VISLab@WPI; by Prof. Haichong (Kai) Zhang at Medical FUSION Lab; and Prof. Markus P. Nemitz at Nemitz Robotics Group. Contact: seanliu0272 [At] gmail [Dot] com
News
- June 30, 2024: Our paper, “Loss Distillation via Gradient Matching for Point Cloud Completion with Weighted Chamfer Distance,” has been accepted for an Oral Presentation at IEEE/RSJ IROS 2024.
- January 31, 2024: Our paper, “Vision-based FDM Printing for Fabricating Airtight Soft Actuators,” has been accepted for an Oral Presentation at IEEE RoboSoft 2024.
Research Vision
My long-term research goal is to build automation systems that can adapt reliably to new environments through trustworthy perception and learned motion strategies grounded in structured reasoning. These systems will assist humans in accomplishing challenging tasks in the physical world.
Selected Publications
Robot Policy Learning
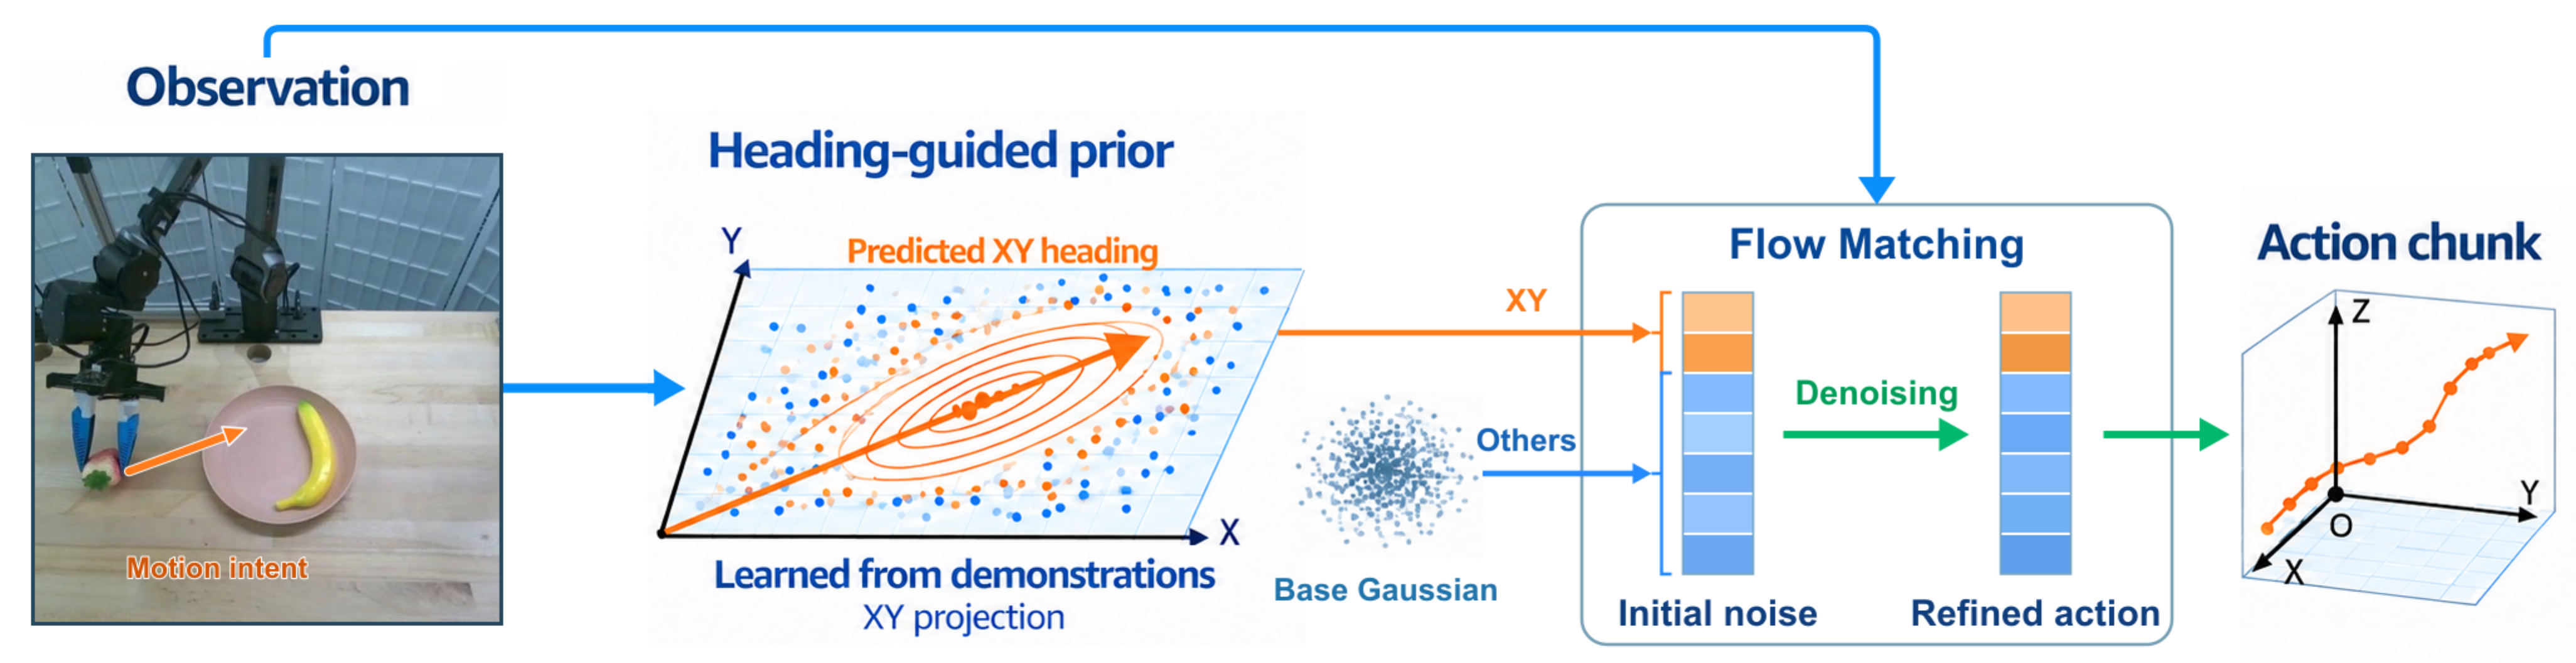
Heading Flow: Guiding Visuomotor Action Generation with Predicted Motion Direction
Haotian Liu, Wei Li, Xin Wen, Yuan Ma, Xin Li, Peijin Jia, Zhen Zhu, Bailin Li, Kun Zhan, Dian Wang
In Submission
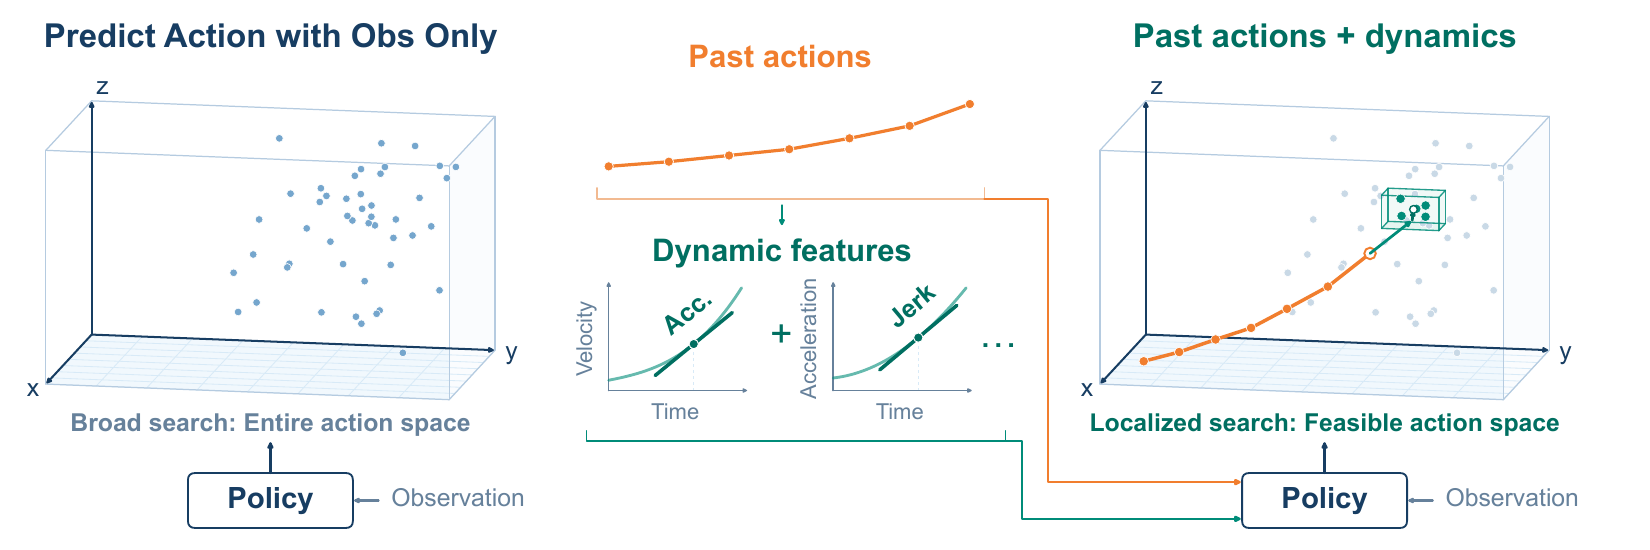
Past2Next: Past Action Conditioning Policy with Data-Augmented Tokenization
Haotian Liu*, Shoukang Yu*, Haojie Huang, Boce Hu, Dian Wang, Robert Platt (* co-first author)
In Submission
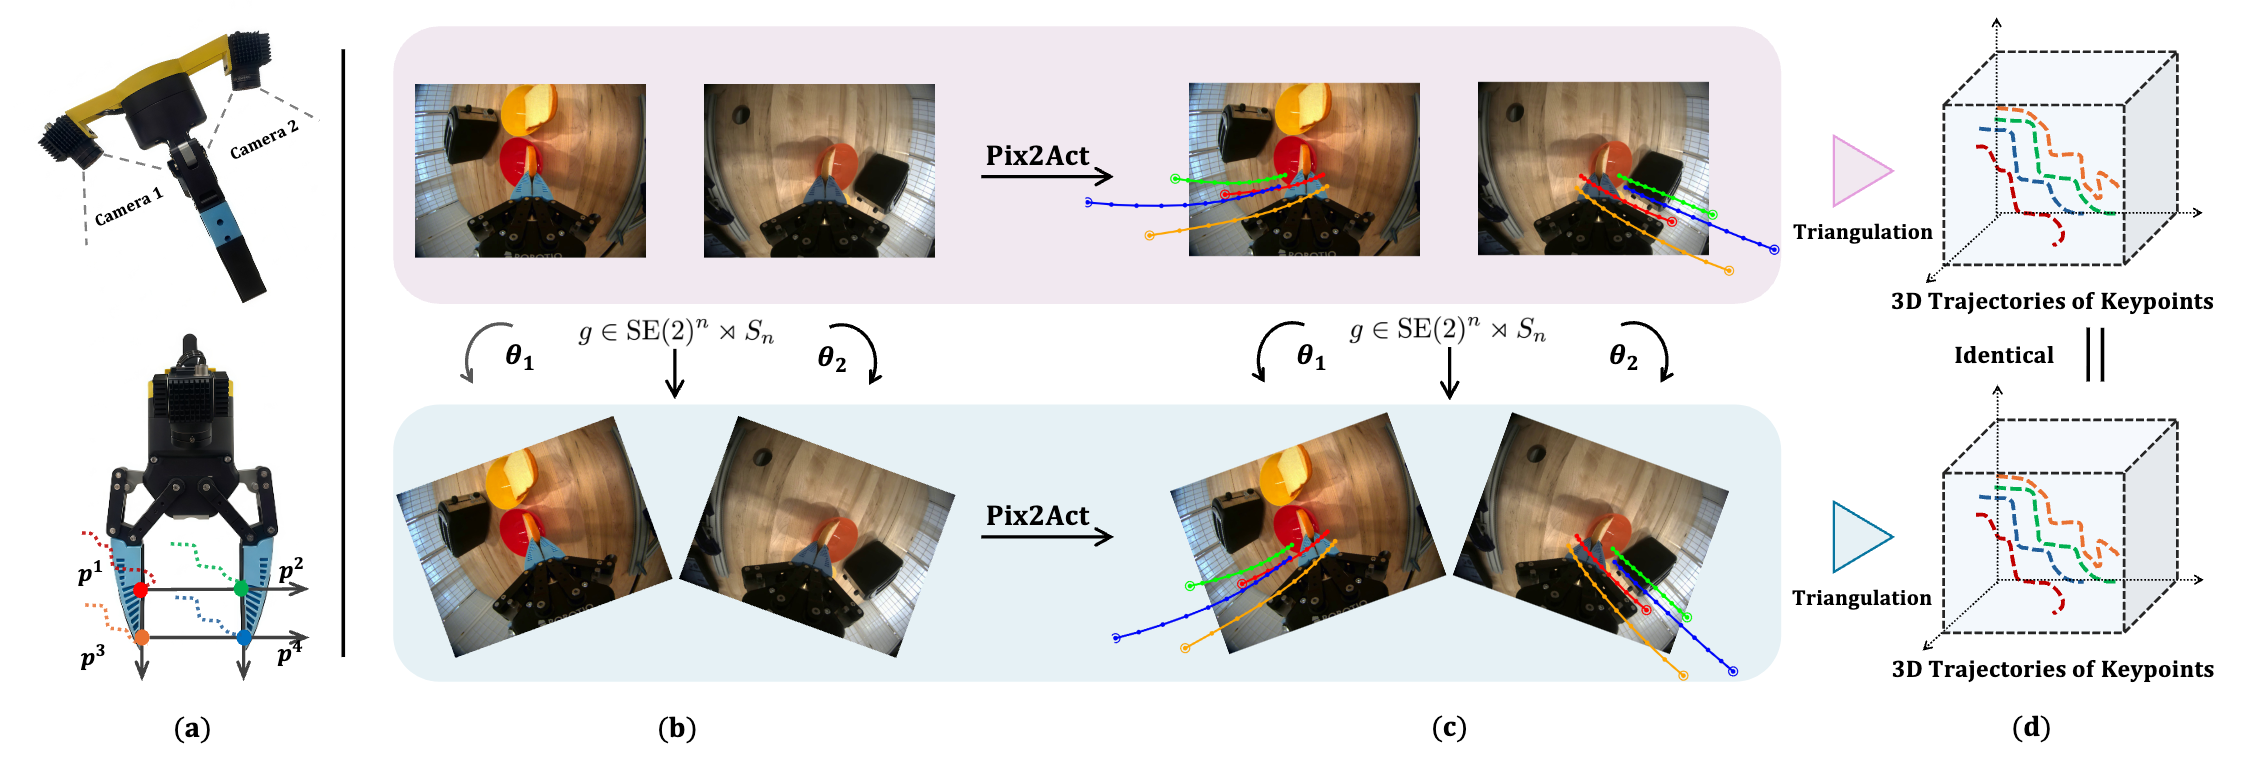
Pix2Act: Image-Space Manipulation Policies with Equivariant Augmentation
Haojie Huang, Linfeng Zhao, Haotian Liu, Zhang Ye, Si-Yuan Huang, Mingxi Jia, Boce Hu, Fangzhou Lin, Yu Qi, Dian Wang, Robin Walters*, Robert Platt* (* Equal Advising)
In Submission, Paper, Project Page
Deep Learning Optimization for 3D Vision
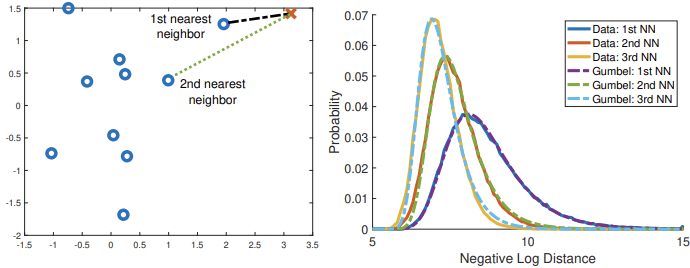
GPS: A Probabilistic Distributional Similarity with Gumbel Priors for Set-to-Set Matching
Haotian Liu*, Fangzhou Lin*, Ziming Zhang*, Jose Morales, Haichong Zhang, Kazunori Yamada, Vijaya B Kolachalama, Venkatesh Saligrama (* co-first author)
International Conference on Learning Representations ICLR 2025 at Singapore, Paper, Code
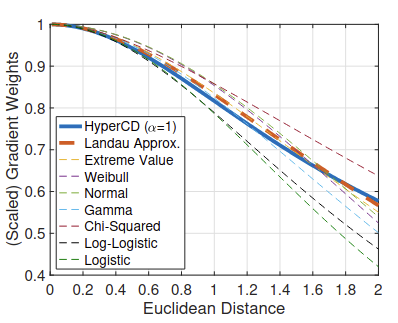
Loss Distillation via Gradient Matching for Point Cloud Completion with Weighted Chamfer Distance
Haotian Liu*, Fangzhou Lin*, Haoying Zhou*, Songlin Hou*, Kazunori Yamada, Gregory S. Fischer, Yanhua Li, Haichong K. Zhang, and Ziming Zhang (* co-first author)
IEEE/RSJ International Conference on Intelligent Robots and Systems IROS 2024 at Abu Dhabi UAE, Oral Presentation, Paper, Code, Presentation
Services
Reviewer of: NeurIPS, ICLR, ICML, CoRL, ICRA